Six proven applications. One Physical AI platform. Each with a measured outcome, a recommended fleet, and the constraint you should know before you start.
Every application below is a loop that closes without a person in the middle. If a workflow still needs someone to notice, fetch, and deliver, the loop is open — and the labour is still there. Pick the loop that costs you most, prove it, then expand.
The AMR reads the buffer and delivers before it empties. The line never waits for someone to notice. 99.7% on-time, WIP down 25%.
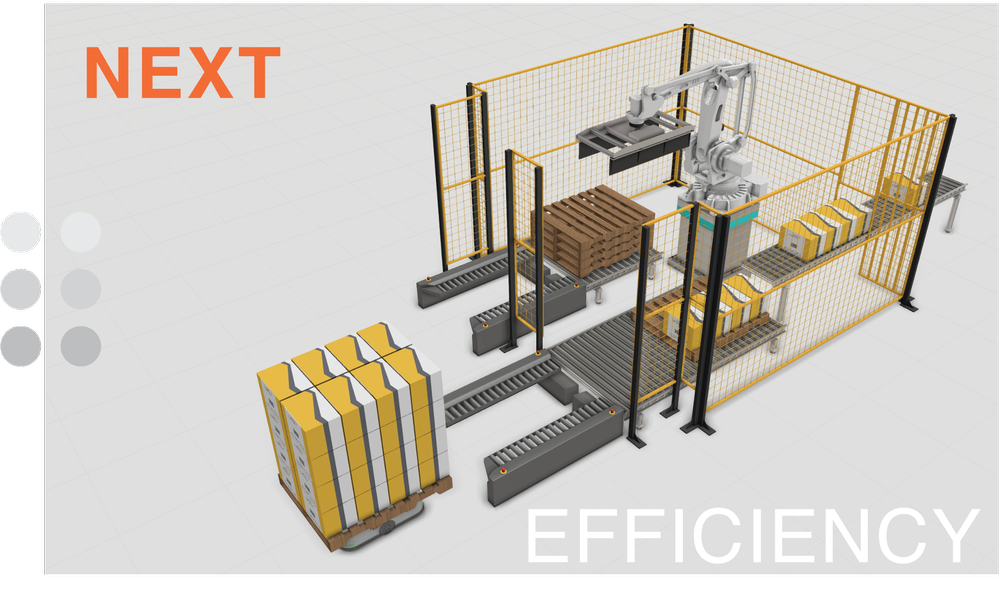
Dock to storage, storage to line, line to dock — routed around congestion instead of waiting in it. 3× throughput, 50% less labour on transport.
Totes and bins come to the station. The picker stays put; the walking leaves the shift. 3× picking throughput.
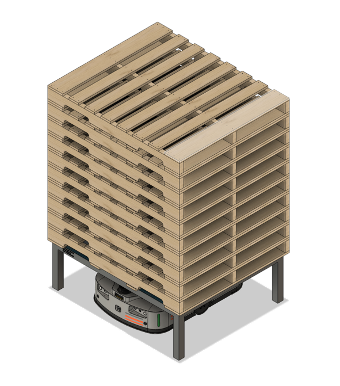
Put-away, retrieval, and high-bay stacking — to 2,000 mm, or 4,500 mm with counterbalance. One robot, two operations.
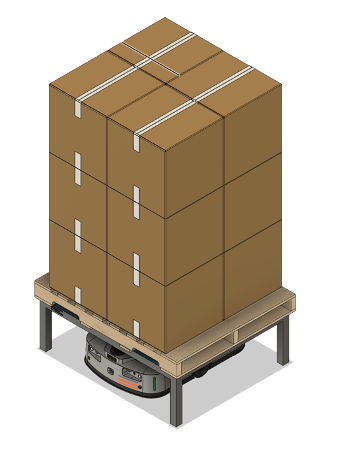
1,500 kg pallets through 2.25 m aisles and 7% ramps — a robot that never cuts the corner.
Receiving through shipping, orchestrated by one Fleet Manager and integrated with your WMS/ERP — up to 50 AMRs.
The open loop. A buffer runs low. Someone notices. Someone fetches. The line waits — four minutes on a good day, longer at shift change.
The closed loop. The AMR reads the buffer level, picks the replacement from staging, and docks before the buffer empties. 99.7% on-time.
Constraint: needs stable staging positions and a defined buffer signal — sensor, WMS call, or scheduled cadence.

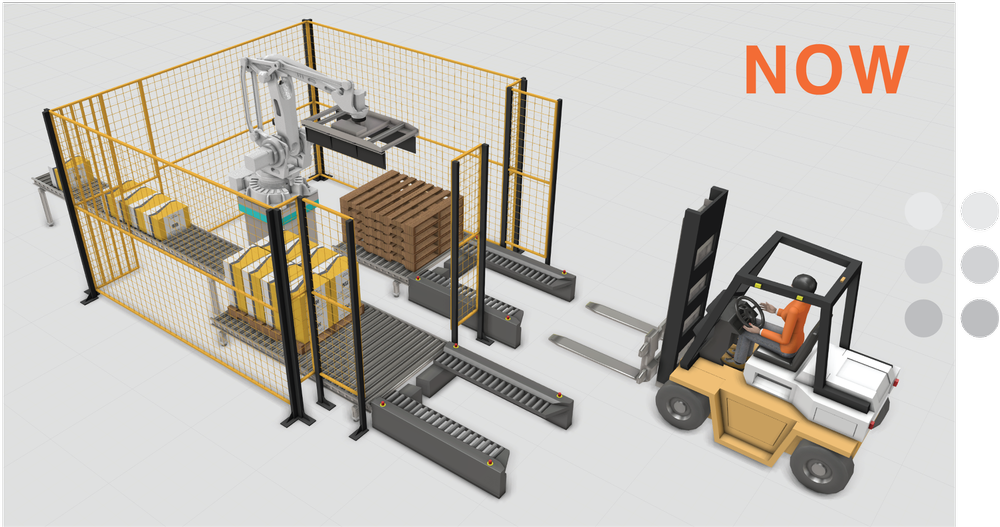
The open loop. A forklift crosses the plant during shift change. Traffic, waits, variability. Throughput depends on who is driving.
The closed loop. Dock to storage, storage to line, line to dock — dynamically routed around congestion. 3× the throughput of manual transport.
Constraint: pallets must sit within the robot's approach envelope. Badly wrapped or off-centre loads are handled during deployment mapping.

The open loop. Pickers walk. Ten to fifteen kilometres a shift — and the walking, not the picking, is the bottleneck.
The closed loop. Totes and bins come to the station. The picker stays put. 3× picking rate.
Constraint: best where SKUs live in totes or bins and the station layout has room for a docking lane.

The open loop. Put-away and retrieval at height, done by hand or by a forklift that could be doing transport work.
The closed loop. One robot moves the pallet across the floor and places it at height — 2,000 mm, or 4,500 mm with counterbalance.
Constraint: aisle width. FX33 operates from 2,338 mm; CX33 needs the clearance a counterbalance truck needs.

The open loop. 1,500 kg pallets through a 2.25 m aisle and a 7% ramp, moved by a driver who has to be right every time.
The closed loop. The same moves, with a robot that never gets tired and never cuts the corner. Safer than a forklift, more consistent than a temp.
Constraint: floor condition and grade. 7% gradeability is the envelope; steeper ramps need a different design conversation.

The open loop. Receiving, put-away, picking, and shipping each optimised separately, with people carrying information between them.
The closed loop. Receiving through shipping, orchestrated by one Fleet Manager, integrated with your WMS/ERP over REST.
Constraint: this is a sequence, not a first project. Close one loop, measure it, then expand to the next.

Someone has to notice, fetch, and deliver. The labour is the loop.
The robot perceives, decides, and acts. Your team handles the exceptions.
Every deployment starts with a single workflow. Proven ROI on one loop funds the next — and the same platform, software, and fleet scale with you.
Pick the highest-cost workflow. Pilot 3–8 AMRs on a defined lane.
Measure throughput, on-time, and labour savings against the baseline.
Extend the same fleet to pallet transport, goods-to-person, and put-away.
Scale to 50+ AMRs, one interface, WMS/ERP integrated. No per-robot SaaS fees.
Tell us the loop that costs you most. We'll walk it, find the constraint, and tell you honestly whether a robot closes it.